gRPC client implementation of a FrameSystem service.
More...
#include <framesystem_client.hpp>
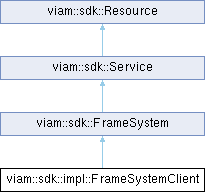
 Inheritance diagram for viam::sdk::impl::FrameSystemClient:
Public Types | |
| using | interface_type = FrameSystem |
Public Member Functions | |
| FrameSystemClient (std::string name, const ViamChannel &channel) | |
| const ViamChannel & | channel () const |
| std::vector< frame_system_config > | get_frame_system_config (const std::vector< WorldState::transform > &additional_transforms) override |
| Get the configuration of every frame in the frame system. | |
| pose_in_frame | get_pose (const std::string &component_name, const std::string &destination_frame, const std::vector< WorldState::transform > &supplemental_transforms, const ProtoStruct &extra) override |
| Get the pose of a component in the desired reference frame. | |
| pose_in_frame | transform_pose (const pose_in_frame &query, const std::string &destination, const std::vector< WorldState::transform > &additional_transforms) override |
| Express a pose in a different reference frame. | |
| std::vector< unsigned char > | transform_pcd (const std::vector< unsigned char > &pcd, const std::string &source, const std::string &destination) override |
| Express a point cloud in a different reference frame. | |
| Public Member Functions inherited from viam::sdk::FrameSystem | |
| std::vector< frame_system_config > | get_frame_system_config () |
| Get the configuration of every frame in the frame system. | |
| pose_in_frame | get_pose (const std::string &component_name) |
| Get the pose of a component in the world reference frame. | |
| pose_in_frame | get_pose (const std::string &component_name, const std::string &destination_frame, const std::vector< WorldState::transform > &supplemental_transforms) |
| Get the pose of a component in the desired reference frame. | |
| pose_in_frame | transform_pose (const pose_in_frame &query, const std::string &destination) |
| Express a pose in a different reference frame. | |
| API | api () const override |
Returns the API associated with a particular resource. | |
| Public Member Functions inherited from viam::sdk::Service | |
| Name | get_resource_name () const override |
Returns the Name for a particular resource. | |
| Public Member Functions inherited from viam::sdk::Resource | |
| Resource (std::string name) | |
| Resource (const ResourceConfig &cfg) | |
| Construct from a resource config. Use this overload to ensure Viam App log filtering works immediately during object construction. | |
| virtual std::string | name () const |
| Return the resource's name. | |
| void | set_log_level (log_level) const |
| Set the log level for log messages originating from this Resource. | |
Additional Inherited Members | |
| Static Public Member Functions inherited from viam::sdk::FrameSystem | |
| static Name | public_name () |
| The full resource name of the machine's frame system. Its short name is kPublicName. | |
| Static Public Attributes inherited from viam::sdk::FrameSystem | |
| static const std::string | kPublicName |
| The reserved name viam-server publishes the machine's frame system under. | |
| Protected Member Functions inherited from viam::sdk::FrameSystem | |
| FrameSystem (std::string name) | |
| FrameSystem (const ResourceConfig &cfg) | |
| Protected Member Functions inherited from viam::sdk::Service | |
| Service (std::string name) | |
| Service (const ResourceConfig &cfg) | |
| Protected Member Functions inherited from viam::sdk::Resource | |
| Name | get_resource_name (const std::string &type) const |
| Protected Attributes inherited from viam::sdk::Resource | |
| LogSource | logger_ |
Detailed Description
gRPC client implementation of a FrameSystem service.
Member Function Documentation
◆ get_frame_system_config()
|
overridevirtual |
Get the configuration of every frame in the frame system.
- Parameters
-
additional_transforms Extra frames to add to the frame system for this call only.
Implements viam::sdk::FrameSystem.
◆ get_pose()
|
overridevirtual |
Get the pose of a component in the desired reference frame.
- Parameters
-
component_name The component whose pose is being requested. destination_frame The reference frame in which to express the pose. supplemental_transforms Extra frames needed to compute the pose. extra Any additional arguments to the method.
Implements viam::sdk::FrameSystem.
◆ transform_pcd()
|
overridevirtual |
Express a point cloud in a different reference frame.
- Parameters
-
pcd The point cloud, serialized in PCD format. source The reference frame the point cloud is currently expressed in. destination The reference frame to express the point cloud in.
- Returns
- The transformed point cloud, serialized in PCD format as raw PCD bytes.
Implements viam::sdk::FrameSystem.
◆ transform_pose()
|
overridevirtual |
Express a pose in a different reference frame.
- Parameters
-
query The pose to transform, with the frame it is currently expressed in. destination The reference frame to express the pose in. additional_transforms Extra frames needed to compute the transform.
Implements viam::sdk::FrameSystem.
The documentation for this class was generated from the following file:
- src/viam/sdk/services/private/framesystem_client.hpp
